PhD in Computer Vision
Juan José Gómez Rodríguez
Software Engineer, XR · Google
About
Welcome to my personal webpage! I'm a software engineer at Google working on XR, where I focus on 3D reconstruction and calibration for the Samsung Galaxy XR and Aura by XREAL.
I completed my PhD in 2023 at the Robotics, Perception and Real Time (RoPeRT) group at the University of Zaragoza, supervised by Prof. Juan D. Tardós. Before that I studied a BSc in Computer Engineering and an MEng in Biomedical Engineering, both at Unizar, where I started my career as a computer vision researcher.
My work is about how computers perceive and understand their surroundings through Visual Simultaneous Localization and Mapping (V-SLAM). I'm especially motivated by situations that break these technologies, like deformable V-SLAM, which has direct applications in fields such as minimally invasive surgery.
Computer Vision
Robotics
Deep Learning
Visual SLAM
Endoscopy
Experience
-
Oct 2024 – Present
Software Engineer, XR
Google · Munich, Germany- 3D reconstruction and calibration for Samsung Galaxy XR and Aura by XREAL
-
Feb – Aug 2024
Computer Vision Software Engineer
Arcturus Industries · Madrid, Spain -
Dec 2023 – Feb 2024
Postdoctoral Researcher
University of Zaragoza · Spain -
Jul – Oct 2023
Software Engineer Intern
Google · Mountain View, USA -
Aug – Oct 2022
Student Researcher
Google · Zürich, Switzerland -
Sep 2018 – Dec 2023
PhD Student & Researcher in Computer Vision
University of Zaragoza · RoPeRT group- Rigid visual SLAM for mobile agents
- Deformable visual SLAM for medical sequences
- Teaching: Introduction to Machine Learning; SLAM
-
Jul – Sep 2018
Computer Vision / SLAM Engineer Intern
Meta · California, USA- Efficient, robust multi-camera SLAM for the Meta 2 AR headset
-
Jun 2017 – Jul 2018
Scholarship Researcher
University of Zaragoza · RoPeRT group- Fisheye-native (monocular and stereo) SLAM built on ORB-SLAM2
- Study of inverse-depth point parametrization in ORB-SLAM2
Education
-
2023
PhD in Computer Vision
University of Zaragoza -
2019
MEng in Biomedical Engineering
University of Zaragoza -
2018
BSc in Computer Engineering
University of Zaragoza
Projects
Publications
Full list on Google Scholar.
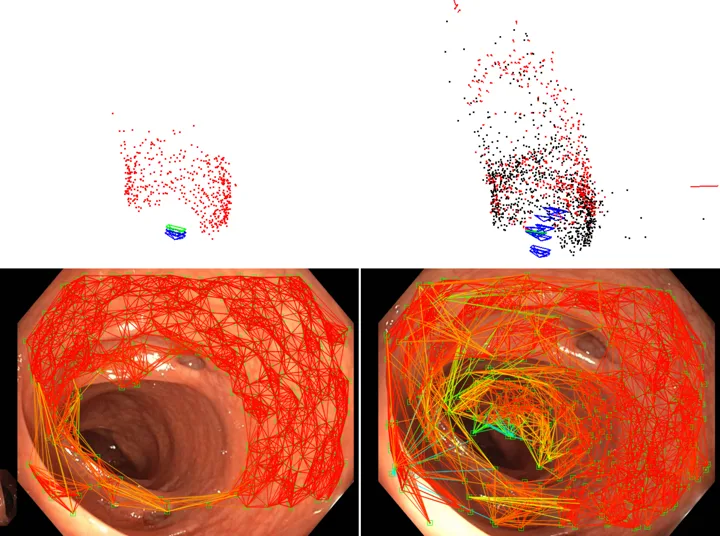
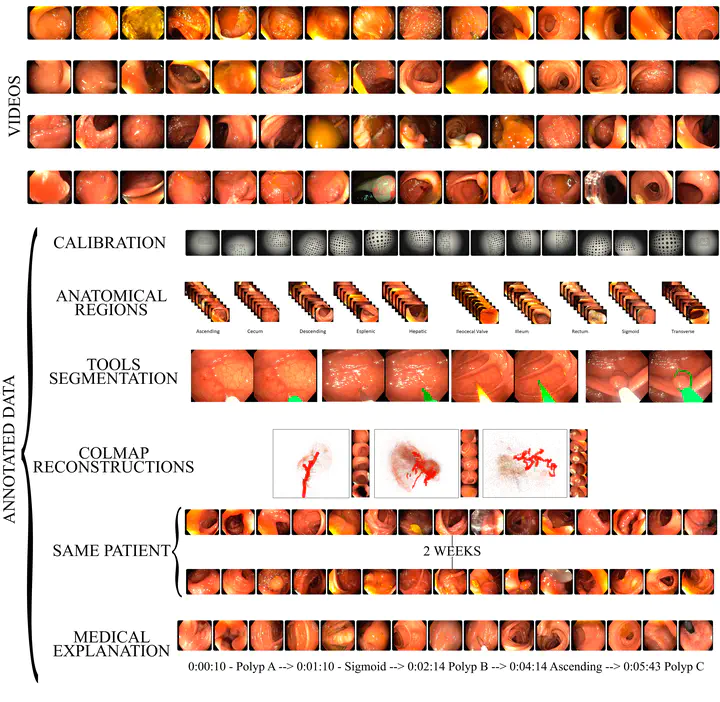
Non-Rigid Monocular SLAM Inside the Human Body
PhD thesis · University of Zaragoza · 2023
Contact
Interested in SLAM, medical vision or collaborating? Drop me a line.